About Me
I’m Zihan Zhou, a Master’s graduate from Boston University actively seeking PhD opportunities in Machine Learning and Computer Vision starting Fall 2026. My research focuses on developing efficient and scalable machine learning systems that bridge the gap between theoretical foundations and practical applications.
Currently, I work as a Research Assistant at Boston University under the supervision of Prof. Reza Rawassizadeh and Prof. Avi Mohan, conducting research on efficient training methods, federated learning, and computer vision.
Research Interests
My work spans several cutting-edge areas in machine learning and computer vision:
- Efficient Training Methods: Developing gradient-based early stopping techniques for transformers that achieve 1.5x-7x training speedup
- 3D Vision & World Models: Exploring novel approaches to scene understanding and temporal prediction
- Federated Learning: Investigating convergence theory and practical implementations for heterogeneous distributed systems
- Continual Learning: Researching methods to prevent catastrophic forgetting in sequential learning tasks
- Pose Estimation & Motion Reconstruction: Building pipelines for motion capture and 3D character animation
Current Research Projects
GradES: Gradient-Based Early Stopping for Transformers
Advisor: Prof. Reza Rawassizadeh | arXiv:2509.01842
Co-authored a paper on component-level early stopping that speeds up transformer training by 1.5x-7x while improving generalization. The method monitors gradient magnitudes at the individual weight matrix level, eliminating expensive validation passes.
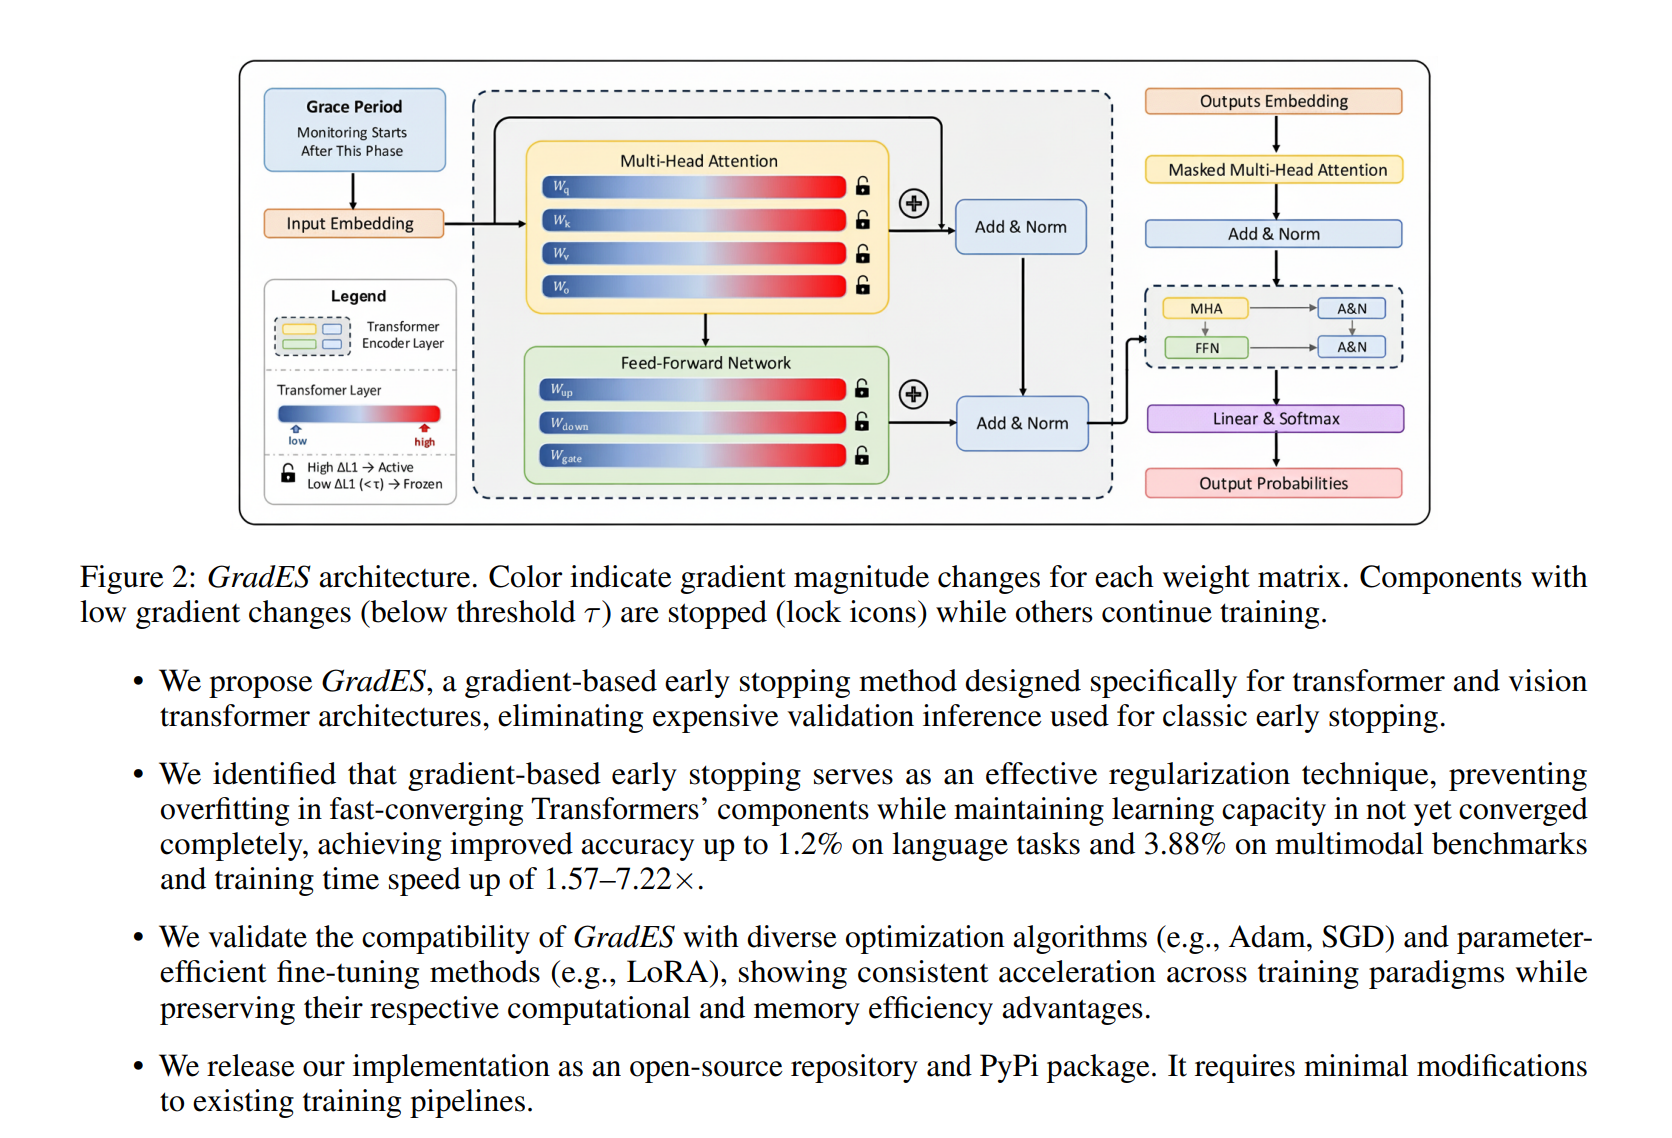
Gradient convergence behavior across transformer components in layer 7 for Qwen3-0.6B, showing distinct convergence rates between MLP and attention projections.
Key Results:
- 29-45% reduction in FLOPs compared to standard fine-tuning
- Consistent accuracy improvements across language and vision-language models
- Tested on models from 0.6B to 14B parameters (Qwen, Phi4, Llama, Mistral)
3D Scene Understanding and Prediction
Developing novel approaches for world modeling that combine scene reconstruction with temporal dynamics using neural representations.
Target: CVPR 2026
Federated Learning: Theory and Practice
Advisor: Prof. Avi Mohan
Investigating convergence theory in federated learning systems through empirical validation on object detection tasks and controlled experiments with heterogeneous data distributions.
Continual Learning in Sequential Tasks
Exploring methods to mitigate catastrophic forgetting in sequential learning scenarios, with focus on maintaining performance across multiple tasks.
Target: ICLR 2026
Education
Master of Science in Computer Science | Boston University (2023 - 2025)
- Research focus: Machine Learning, Computer Vision, Federated Learning
Bachelor of Science in Computer Science | Hobart and William Smith Colleges (2019 - 2023)
- Location: Geneva, NY
Technical Skills
- Deep Learning Frameworks: PyTorch, TensorFlow
- Computer Vision: 3D Gaussian Splatting, Pose Estimation, Object Detection
- Distributed Systems: Federated Learning (Flower), Multi-GPU Training
- Research Tools: Wandb, Git, Docker, Jupyter